Let us consider to the example of a mass on a spring. We now examine the case of forced oscillations, which we did not yet handle. That is, we consider the equation
for some nonzero . The setup is again: is mass, is friction, is the spring constant, and is an external force acting on the mass.
Interactive figureThe apparatus itself: mass, spring, damper, driving forceDrag the Time t and Forcing frequency ω (natural = 1) sliders.
XYZ Graph · viewer build 5edf91b
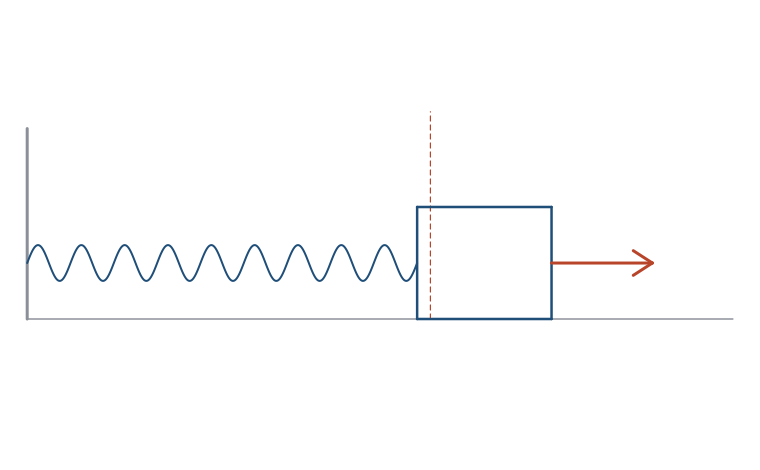
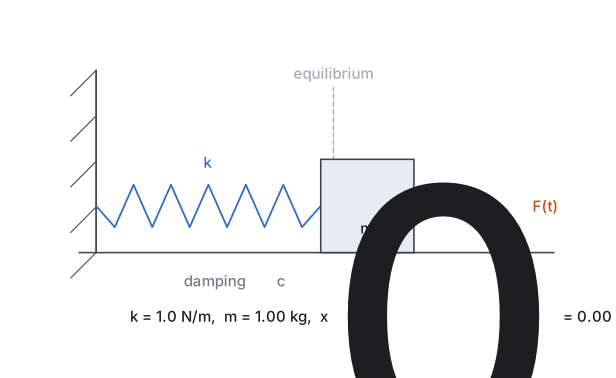
Figure 1's setup, made to move. The section's own m = k = 1 with damping c = 0.4, driven by F₀cos(ωt). Drag Time and the block travels; drag the forcing frequency and the travel changes size. Near ω = 1, which is this system's natural frequency, the block swings far wider than the driving arrow ever gets — that is resonance, on the apparatus rather than on a graph. Away from 1 in either direction it barely moves. Watch the arrow against the block: at low frequency they go the same way together, at ω = 1 the block is a quarter period behind, and above 1 the block is moving left while the force pushes right. The dashed line is the equilibrium position the block would rest at with no forcing.Figure
What we are interested in is periodic forcing, such as noncentered rotating parts, or perhaps loud sounds, or other sources of periodic force. Once we learn about Fourier series in Chapter 4, we will see that we cover all periodic functions by simply considering (or sine instead of cosine, the calculations are essentially the same).
Undamped Forced Motion and Resonance
First let us consider undamped motion for simplicity. We have the equation
This equation has the complementary solution (solution to the associated homogeneous equation)
where is the natural frequency (angular), which is the frequency at which the system “wants to oscillate” without external interference.
Let us suppose that . We try the solution and solve for . Note that we need not have sine in our trial solution as on the left hand side we will only get cosines anyway. If you include a sine it is fine; you will find that its coefficient will be zero.
We solve using the method of undetermined coefficients. We find that
We leave it as an exercise to do the algebra required.
The general solution is
or written another way
Hence it is a superposition of two cosine waves at different frequencies.
Now suppose that . Obviously, we cannot try the solution and then use the method of undetermined coefficients. We notice that solves the associated homogeneous equation. Therefore, we need to try . This time we do need the sine term since the second derivative of does contain sines. We write the equation
Plugging into the left hand side we get
Hence and . Our particular solution is and our general solution is
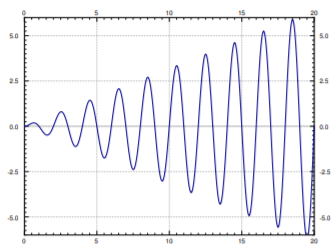
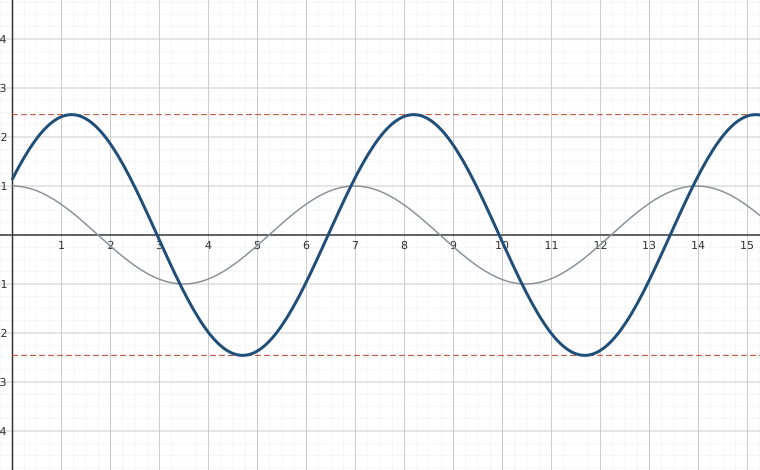
The important term is the last one (the particular solution we found). We can see that this term grows without bound as . In fact it oscillates between and . The first two terms only oscillate between , which becomes smaller and smaller in proportion to the oscillations of the last term as gets larger. In Figure we see the graph with .
Figure : Graph of .
By forcing the system in just the right frequency we produce very wild oscillations. This kind of behavior is called resonance or perhaps pure resonance. Sometimes resonance is desired. For example, remember when as a kid you could start swinging by just moving back and forth on the swing seat in the “correct frequency”? You were trying to achieve resonance. The force of each one of your moves was small, but after a while it produced large swings.
Interactive figureBeating stretching toward pure resonance as the forcing frequency approaches ω₀Drag the Forcing frequency slider from 2.8 to 3.6.
XYZ Graph · viewer build 5edf91b
This section's own example 0.5x″ + 8x = 10cos(ωt) with x(0) = x′(0) = 0, generalized to a draggable ω and drawn with the slow modulating wave Lebl's own product identity gives: x = 40/(16 − ω²)·sin(((4−ω)/2)t)·sin(((4+ω)/2)t). At the default ω = π it reproduces Figure 2 exactly. Drag ω toward ω₀ = 4 and the beat period 4π/(4 − ω) stretches from about 10 s to about 31 s while the peak amplitude 40/(16 − ω²) climbs from 4.9 to 13.2. That prefactor diverges at ω = ω₀ — which is precisely why this closed form breaks down at resonance, and why the resonant case needs the separate growing solution (F₀/2mω₀)·t·sin(ω₀t), the shape plotted in Figure 3.
On the other hand resonance can be destructive. In an earthquake some buildings collapse while others may be relatively undamaged. This is due to different buildings having different resonance frequencies. So figuring out the resonance frequency can be very important.
A common (but wrong) example of destructive force of resonance is the Tacoma Narrows bridge failure. It turns out there was a different phenomenon at play.1
Damped Forced Motion and Practical Resonance
In real life things are not as simple as they were above. There is, of course, some damping. Our equation becomes
Interactive figureThe driven mass: how big the response is, and how far behind the forcingDrag the Forcing frequency ω (ω₀ = 1) and Damping coefficient c sliders.
XYZ Graph · viewer build 5edf91b
Equation (2.6.1) with the section's own normalisation m = k = F₀ = 1, so ω₀ = 1 and the height of the response is exactly the practical-resonance amplitude plotted further down. The pale curve is the forcing cos(ωt); the heavy curve is the steady periodic response x_sp, drawn in Lebl's own A cos(ωt) + B sin(ωt) form with A = (1 − ω²)/D and B = cω/D, D = (1 − ω²)² + (cω)². Drag the forcing frequency: the response swells as ω approaches ω₀ = 1 and shrinks away on either side, and it also slides to the right of the forcing. At ω = ω₀ exactly, A = 0, the response is a pure sine, and the lag is a quarter period — Lebl's γ = π/2. Push ω past 1 and the lag keeps growing toward half a period, so a fast-driven mass ends up moving opposite to the force pushing it. Damping sets how tall the peak gets, not where it is.
(2.6.1)
for some . We have solved the homogeneous problem before. We let
The roots of the characteristic equation of the associated homogeneous problem are . The form of the general solution of the associated homogeneous equation depends on the sign of , or equivalently on the sign of , as we have seen before. That is,
where . In any case, we can see that as . Furthermore, there can be no conflicts when trying to solve for the undetermined coefficients by trying . Let us plug in and solve for and . We get (the tedious details are left to reader)
We get that
We also compute to be
Thus our particular solution is
Or in the alternative notation we have amplitude and phase shift where (if )
Hence we have
If we see that .
The exact formula is not as important as the idea. Do not memorize the above formula, you should instead remember the ideas involved. For different forcing function , you will get a different formula for . So there is no point in memorizing this specific formula. You can always recompute it later or look it up if you really need it.
For reasons we will explain in a moment, we call the transient solution and denote it by . We call the we found above the steady periodic solution and denote it by . The general solution to our problem is
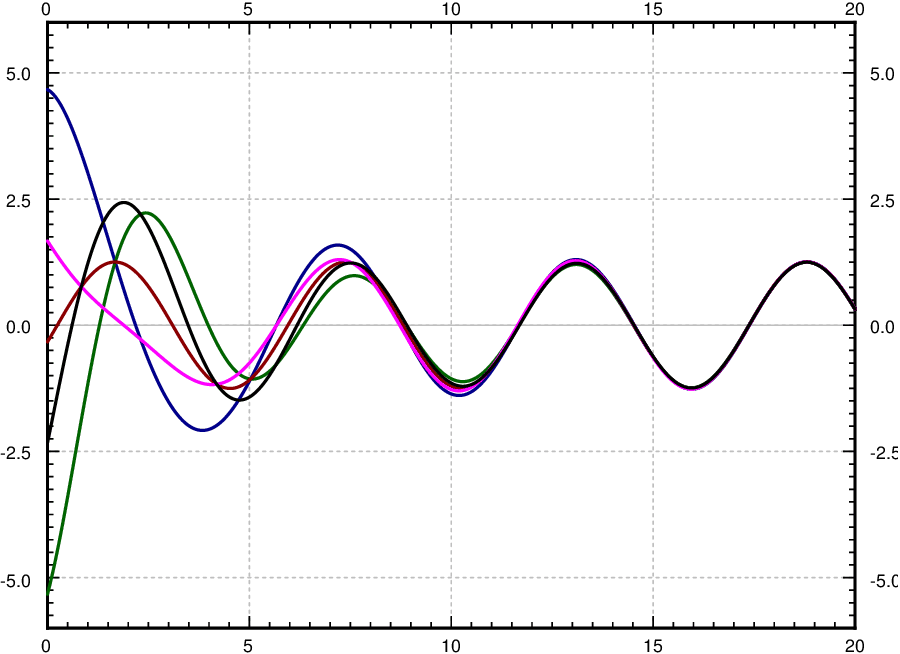
We note that goes to zero as , as all the terms involve an exponential with a negative exponent. Hence for large , the effect of is negligible and we will essentially only see . Hence the name transient. Notice that involves no arbitrary constants, and the initial conditions will only affect . This means that the effect of the initial conditions will be negligible after some period of time. Because of this behavior, we might as well focus on the steady periodic solution and ignore the transient solution. See Figure for a graph of different initial conditions.
Figure : Solutions with different initial conditions for parameters and
Notice that the speed at which goes to zero depends on (and hence ). The bigger is (the bigger is), the “faster” becomes negligible. So the smaller the damping, the longer the “transient region.” This agrees with the observation that when , the initial conditions affect the behavior for all time (i.e. an infinite “transient region”).
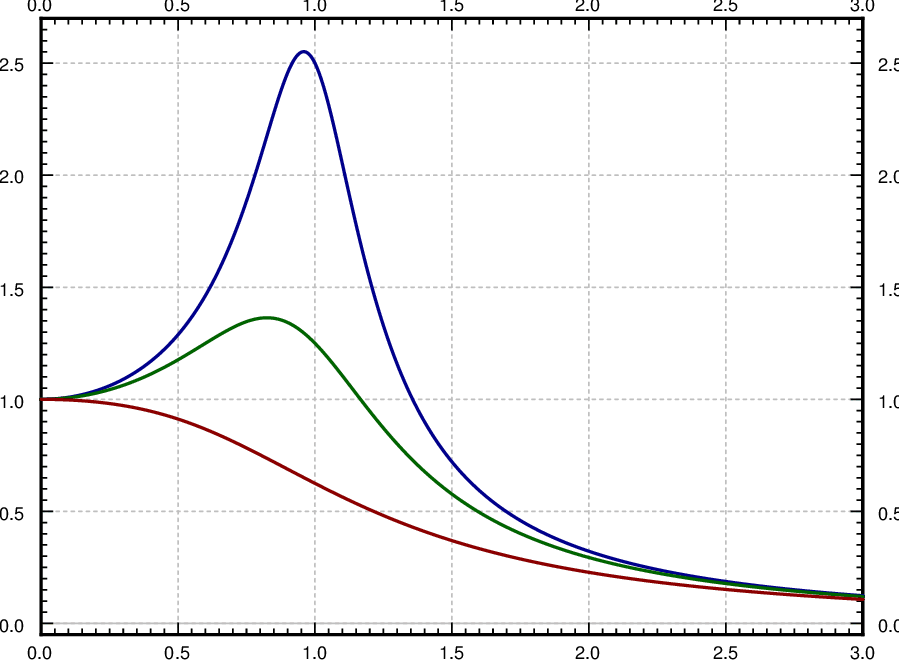
Let us describe what we mean by resonance when damping is present. Since there were no conflicts when solving with undetermined coefficient, there is no term that goes to infinity. What we will look at however is the maximum value of the amplitude of the steady periodic solution. Let be the amplitude of . If we plot as a function of (with all other parameters fixed) we can find its maximum. We call the that achieves this maximum the practical resonance frequency. We call the maximal amplitude the practical resonance amplitude. Thus when damping is present we talk of practical resonance rather than pure resonance. A sample plot for three different values of is given in Figure . As you can see the practical resonance amplitude grows as damping gets smaller, and any practical resonance can disappear when damping is large.
Interactive figurePractical resonance: steady-periodic amplitude C(ω) against dampingDrag the Damping coefficient slider from 0.3 to 2.
XYZ Graph · viewer build 5edf91b
The steady-periodic amplitude C(ω) for this section's own parameters m = k = F₀ = 1, so ω₀ = 1 and p = c/2. Figure 5's three frozen curves are three ticks of this one slider — set c to 0.4, 0.8 and 1.6 to reproduce them. Drag c upward and watch the peak slide left of ω₀ and collapse, then vanish entirely as c crosses √2 ≈ 1.414, the exact threshold ω₀² − 2p² > 0 derived just below.Figure : Graph of showing practical resonance with parameters . The top line is with , the middle line with , and the bottom line with .
To find the maximum we need to find the derivative . Computation shows
This is zero either when or when . In other words, when
It can be shown that if is positive, then is the practical resonance frequency (that is the point where is maximal, note that in this case for small ). If is the maximum, then essentially there is no practical resonance since we assume that in our system. In this case the amplitude gets larger as the forcing frequency gets smaller.
If practical resonance occurs, the frequency is smaller than . As the damping (and hence ) becomes smaller, the practical resonance frequency goes to . So when damping is very small, is a good estimate of the resonance frequency. This behavior agrees with the observation that when , then is the resonance frequency.
Another interesting observation to make is that when , then . This means that if the forcing frequency gets too high it does not manage to get the mass moving in the mass-spring system. This is quite reasonable intuitively. If we wiggle back and forth really fast while sitting on a swing, we will not get it moving at all, no matter how forceful. Fast vibrations just cancel each other out before the mass has any chance of responding by moving one way or the other.
The behavior is more complicated if the forcing function is not an exact cosine wave, but for example a square wave. A general periodic function will be the sum (superposition) of many cosine waves of different frequencies. The reader is encouraged to come back to this section once we have learned about the Fourier series.
Footnotes
1K. Billah and R. Scanlan, Resonance, Tacoma Narrows Bridge Failure, and Undergraduate Physics Textbooks, American Journal of Physics, 59(2), 1991, 118–124, http://www.ketchum.org/billah/Billah-Scanlan.pdf
These eBooks are a prerelease and are not yet certified conformant with WCAG 2.1 AA or ADA Title II. Every page is built against an automated accessibility gate, and the published editions will meet ADA Title II requirements when they release in late September 2026. If something is unusable, please tell us.